 Richard's Blog
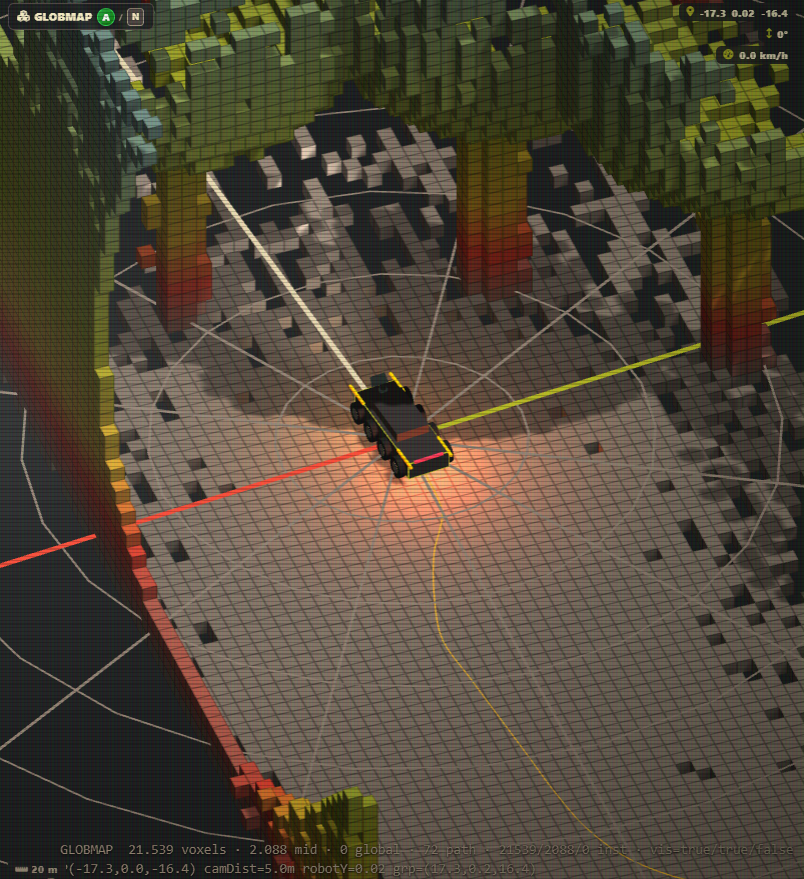
A code-level tour of IGNIS-8's LiDAR-inertial odometry: a FAST-LIO-style error-state Kalman filter fusing the L1 PM's 250 Hz IMU with its 20 Hz point cloud into a 6-DOF pose, plus a keyframe-based loop closer that detects revisits, confirms them by scan match and rebuilds the four-level voxel map without drift.
slam
Tag: slam#
Cutting the thermal stream and SLAM load on IGNIS-8
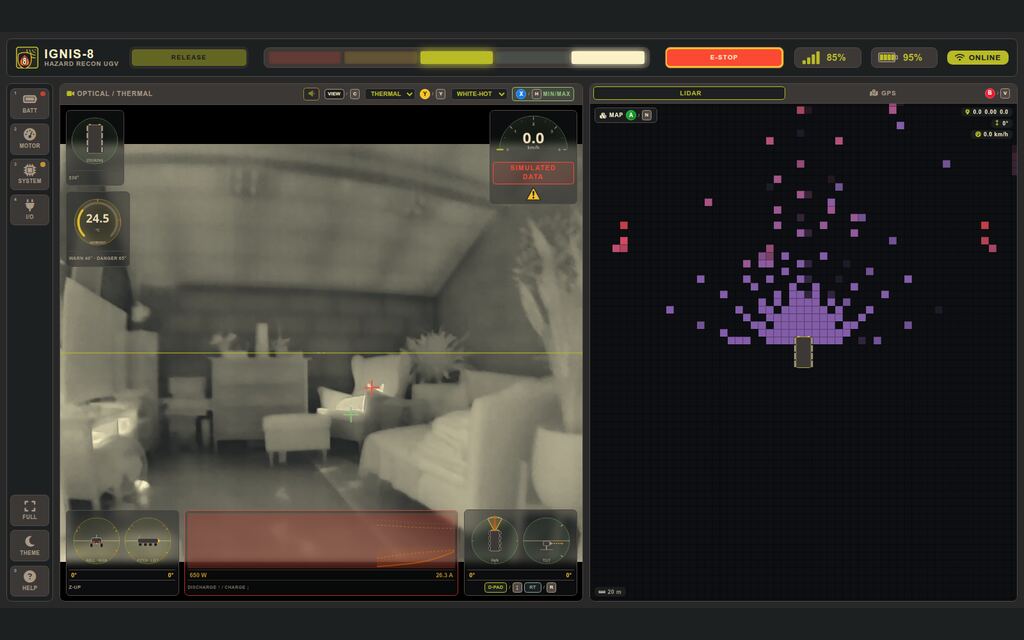
Why my reconnaissance UGV kept throwing OVERLOAD, and how a lookup-table palette, a frame-rate cap and an offscreen raster blit took the thermal stream and the SLAM map from a saturated CPU to a smooth ride.