 Richard's Blog
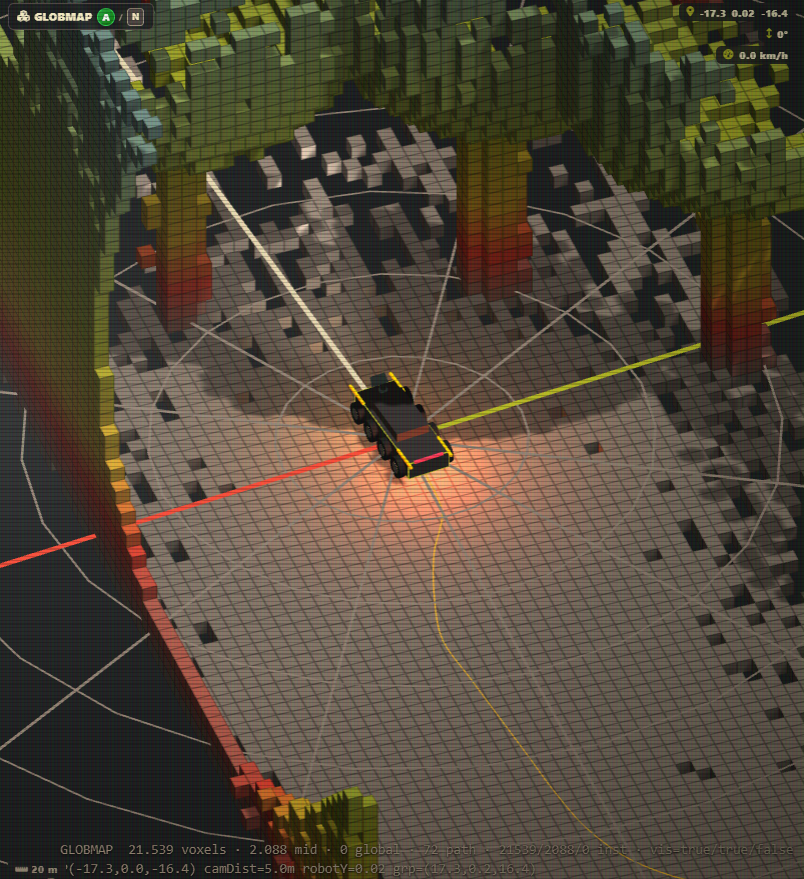
A code-level tour of IGNIS-8's LiDAR-inertial odometry: a FAST-LIO-style error-state Kalman filter fusing the L1 PM's 250 Hz IMU with its 20 Hz point cloud into a 6-DOF pose, plus a keyframe-based loop closer that detects revisits, confirms them by scan match and rebuilds the four-level voxel map without drift.
ignis8
About IGNIS-8#
IGNIS-8 is a remotely operated 4-axle, 8-wheel unmanned ground vehicle with all-wheel drive and all-wheel steering. It is built as a 1:5 scale platform for battery-hazard reconnaissance: it approaches damaged or hazardous battery packs from a safe distance, inspects them and streams back live telemetry.
This section documents the build — chassis and suspension, drivetrain, battery and power topology, the control system and the firmware that runs the vehicle.
Articles#
Arming the drive: a fail-safe by default
Why IGNIS-8's drive starts disarmed like a drone: a fail-safe-by-default arm gate that only lets the vehicle move after the operator deliberately enables it, and that re-disarms automatically on every watchdog timeout or emergency stop.
Emergency stop: a latch that never releases itself
Why IGNIS-8's emergency stop is a latched, multi-source system that never resets itself: two independent latches, battery and operator triggers, a manual-only release, and a stop that is selective — the drives release while the camera gimbal and sensors stay live.
Cutting the thermal stream and SLAM load on IGNIS-8
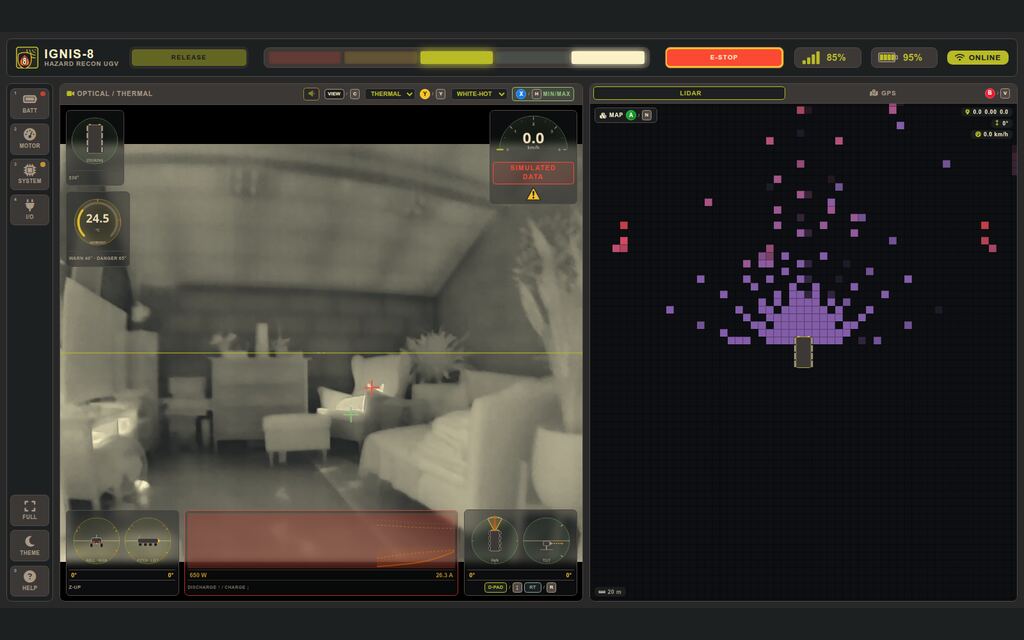
Why my reconnaissance UGV kept throwing OVERLOAD, and how a lookup-table palette, a frame-rate cap and an offscreen raster blit took the thermal stream and the SLAM map from a saturated CPU to a smooth ride.
Battery rethink: prismatic PHEV1 vs cylindrical M50L
Comparing the Samsung PHEV1 prismatic 6S2P pack against a 6S21P LG INR21700M50L cylindrical candidate for IGNIS-8: OCV and power-limit curves, weight and space, and how both cell models are selectable in the VCU config.
The technical hurdles between the drawing board and the first drive
The problems between the drawing board and a working vehicle: a browser-fed watchdog that flipped the OVERLOAD badge, a palette filter that ate nine cores, a camera that refused to follow orders, and a map that stalled the handheld.
Project start
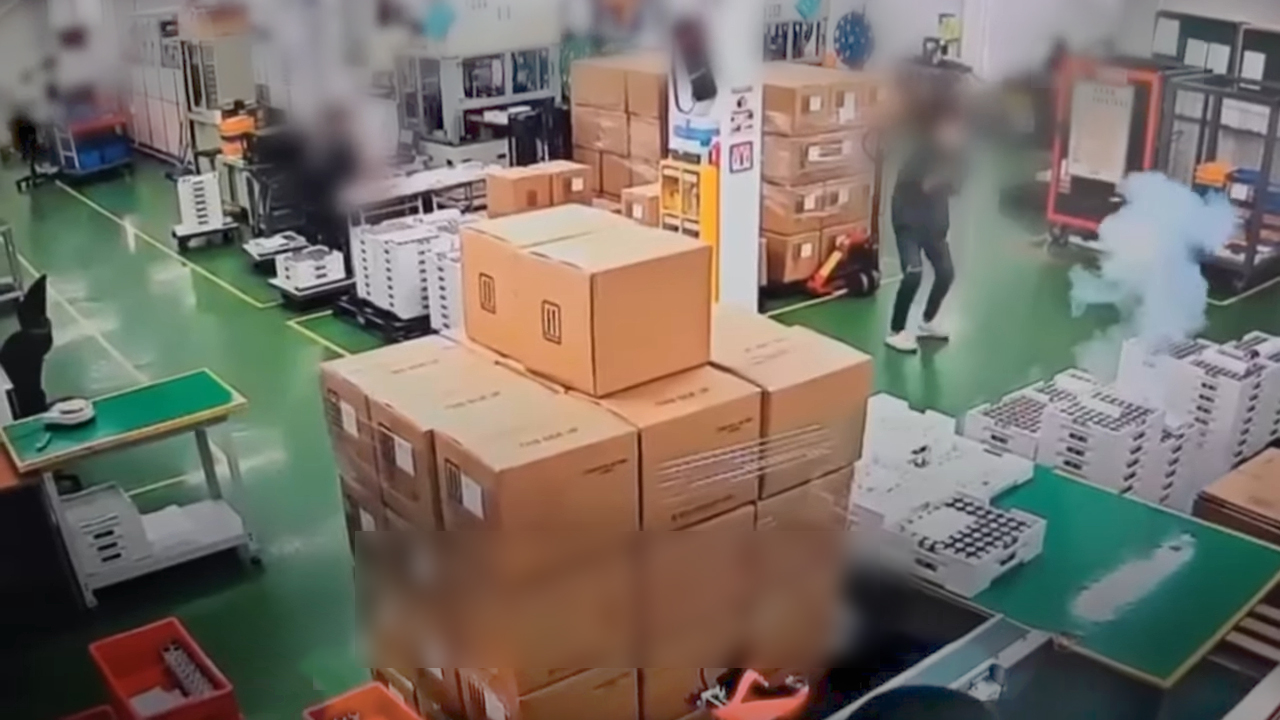
How IGNIS-8 came to be: a swollen cell on a battery production floor, a phone call, and the idea of a remotely operated platform that could look at it from a safe distance.